Buyer's guide · Updated quarterly
Teleoperation hardware in 2027: controllers, kits and rigs compared
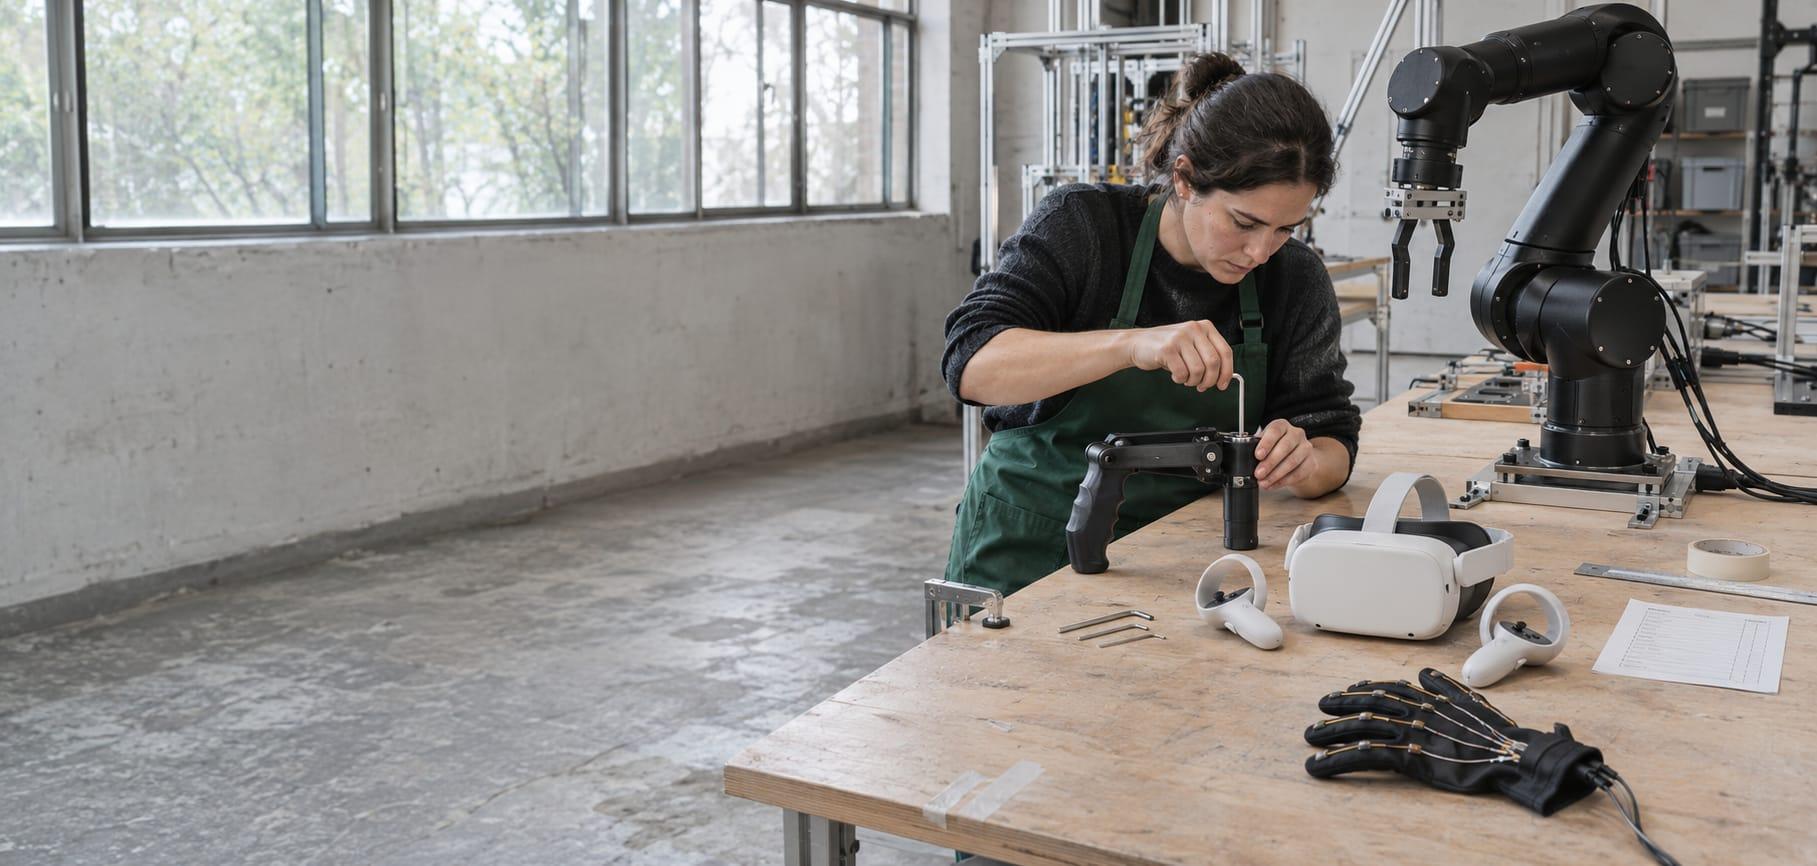
Nine ways to put a robot under a person's control, from a $230 pair of printed arms to a $24,000 bimanual station, compared on what they cost and what they record, followed by the line most hardware budgets leave out, the operators.
Contents
In brief
There is no single best teleoperation controller, because each one records something different. Leader arms record joint positions, headsets record head and hand poses, gloves record fingers. Published prices run from $229.88 in parts to $23,995.95 for a complete station. The controller is also the smaller cost: at the pay rates robot operators are offered, wages pass the price of most rigs within weeks. These are the strongest fits by situation.
- The people to run the rig: RoboPilots. Pilots trained on your robot connect through your own teleoperation stack or its SDK, from $12 an hour.
- A first dataset on a small budget: SO-101 leader and follower arms. $229.88 in parts for a leader and follower pair, with recording built into LeRobot.
- A Franka, UR5 or xArm you already own: GELLO. A printed replica of the arm for under $300 that controls it in joint space.
- A supported bimanual station: Trossen AI kits and Glide. Four arms, four cameras and a frame for $23,995.95, built in two to three weeks.
- One controller for many robots: Meta Quest 3. A consumer headset that reports head and wrist poses, used to collect the DROID dataset.
- Multi-fingered robot hands: MANUS Metagloves Pro. A commercial glove that measures 25 degrees of freedom per hand, priced by quote.
A purchase that looks like the whole decision
A robotics team that has decided to run its own teleoperation starts by shopping. The search results are hard to use. A printed arm pair costs $229.88 in parts1. A bimanual station with the same basic idea costs $23,995.952. A consumer headset sits between them, and research papers describe gloves and exoskeletons that exist only as build instructions. Product pages list what a device is made of more often than what it records, and several commercial ones give no price at all345.
The stakes are higher than the prices suggest, because the controller fixes the shape of the data. A leader arm produces joint positions for one robot. A headset produces hand poses that software must convert. A handheld gripper produces video with no robot in it. A team that buys the wrong one finds out when the first policy is trained.
There is also a second purchase hiding behind the first. Every option in this guide needs a trained person holding it, for as many hours as the data plan requires. The hardware is a one-time cost. The operators are not, and their cost is the subject of the second half of this guide.
How we compared the options
We reviewed nine pieces of teleoperation hardware and one service that supplies the operators. Each was assessed on the same six criteria: published price, degrees of freedom, what it records, which robots its source names, whether the design is open, and whether trained operators come with it. Facts come from the maker's page, the authors' paper or project page, or dated press, each opened on the date shown in the sources. Figures that makers or authors report about their own work are labeled as theirs. The rules are on the methodology page.
The frame is one situation: a team with its own robot that plans to staff teleoperation itself and is choosing what its people will hold.
The options, by job
1. RoboPilots
Trained remote pilots
Best for: Teams that have a robot and a way to drive it, and would rather not recruit, train and schedule the people who do the driving.
RoboPilots is not hardware. It supplies remote pilots who are trained on the customer’s robot, connect through the RoboPilots SDK or the customer’s own teleoperation stack and return each session as labeled episodes in LeRobot, RLDS or HDF5. It publishes a starting price of $12 an hour and quotes everything above that on the fleet.
2. SO-101 leader and follower arms
Open-source leader-follower kit
Best for: A first dataset and a first trained policy on the smallest budget, with software that records and uploads episodes out of the box.
The SO-101 is a 3D-printed arm designed by TheRobotStudio with Hugging Face, sold as a matched pair: a leader the operator moves by hand and a follower that copies it. The published bill of materials for both arms is $229.88 in the United States, and Hugging Face’s LeRobot library teleoperates, records and trains on it with documented commands.
3. GELLO
Open-source leader arm
Best for: Teams that already own a Franka, UR5 or xArm and want joint-space control of it for a few hundred dollars.
GELLO, from UC Berkeley, is a framework for building a scaled, kinematically equivalent replica of a robot arm from 3D-printed parts and off-the-shelf motors. The operator moves the replica and the robot’s joints follow. The authors state that the parts cost less than $300 and that assembly takes about 30 minutes.
4. Trossen AI kits and Glide
Commercial ALOHA-style kits
Best for: Labs and startups that want a supported bimanual leader-follower station delivered in weeks, with published prices.
Trossen Robotics sold the kit version of ALOHA and has replaced it with the Trossen AI line. The Stationary AI kit, with two leader-follower arm pairs and four depth cameras, is listed at $23,995.95. Its separate Glide leader arm, a passive encoder-only controller, is $2,495, or $6,995 as a pair with the Cockpit station.
5. Meta Quest 3
VR headset and hand controllers
Best for: A low-cost, widely supported way to drive an arm or a humanoid’s upper body by hand pose, including from another building.
The Quest is the consumer headset most open teleoperation software supports. The headset tracks the head and the controllers track the wrists, and software converts those poses into robot commands. The DROID dataset, 76,000 trajectories, was collected with the earlier Quest 2 and its controllers. UploadVR reported the 512 GB Quest 3 at $600 after a price rise in April 2026.
6. Apple Vision Pro
Mixed-reality headset with hand tracking
Best for: Bimanual dexterous hands and humanoid upper bodies, where bare-hand finger tracking without controllers is the point.
Apple Vision Pro tracks the operator’s head, wrists and fingers without handheld controllers, which is why several research systems use it to drive robot hands. Bunny-VisionPro converts its hand poses into commands for two dexterous hands in real time, and Unitree names it among the headsets its humanoid software supports. Apple’s price starts at $3,499.
7. MANUS Metagloves Pro
Commercial finger-tracking glove
Best for: Teams driving a multi-fingered robot hand that want a supported commercial glove with a ROS 2 integration.
MANUS Metagloves Pro track the hand with electromagnetic-field sensors and, per the maker, capture 25 degrees of freedom of a full anatomical hand model. The product page lists ROS 2 among its integrations. The price is by quote. Shadow Robot offers the haptic version of the glove as one of three glove options in its teleoperation system.
8. DOGlove
Open-source haptic glove
Best for: Research teams that want finger capture with force feedback and are willing to build the glove themselves.
DOGlove, published at RSS 2025, is an open-source glove that captures 21 degrees of freedom of hand motion and returns 5 degrees of force feedback and 5 of fingertip vibration. The authors state that it can be assembled in hours for under $600. They demonstrate it driving the LEAP robot hand.
9. AirExo
Open-source arm exoskeleton
Best for: Whole-arm demonstrations on a research arm, including collection away from the robot.
AirExo is a wearable dual-arm exoskeleton from Shanghai Jiao Tong University with a one-to-one joint mapping to the robot. The authors put its cost at approximately $300 per arm. It was developed for Flexiv Rizon arms and, they state, can be modified for the UR5, Franka and Kuka. Worn without the robot, it records demonstrations in the wild.
10. UMI gripper
Handheld capture gripper
Best for: Collecting many gripper demonstrations quickly, in real places, with no robot on site.
The Universal Manipulation Interface is a handheld parallel-jaw gripper with a GoPro camera mounted on it. A person performs the task with the gripper and the recording trains a policy that runs on a robot. The authors deployed the same policy on UR5e and Franka arms and report 111 demonstrations an hour on a cup task, against 35 with space-mouse teleoperation.
RoboPilots is listed first for a reason the rest of the list makes plain. Every other row answers "what will the operator hold". None answers "who is the operator". RoboPilots is the one option reviewed that supplies trained people rather than a device, and it works with a rig the team has already built, connecting through its SDK or the customer's own teleoperation stack6. A team should choose its hardware first on the evidence below, then decide who runs it.
The rig comparison table
| Option | Published price | Degrees of freedom | What it records | Supported robots | Open design | Operators included |
|---|---|---|---|---|---|---|
| 1. RoboPilots | Yes. From $12 an hour | —. Uses your rig or its SDK | Yes. Labeled episodes: LeRobot, RLDS, HDF5 | Yes. Arms, humanoids, drones, wheeled, quadrupeds | —. A service, not a design | Yes. Pilots trained on your robot |
| 2. SO-101 leader and follower arms | Yes. $229.88 parts, both arms | 5 joints plus gripper | Joint positions and camera video | SO-101 follower | Yes. Hardware and software | No. You hire and train |
| 3. GELLO | Yes. Under $300 in parts (authors) | Matches the target arm’s joints | Joint positions | Franka, UR5, xArm | Yes. Hardware and software | No. You hire and train |
| 4. Trossen AI kits and Glide | Yes. $23,995.95 (Stationary AI) | Not stated on the page | Joint positions, four camera streams | WidowX AI followers; Glide also UR3e | Partly. Open SDK; commercial hardware | No. You hire and train |
| 5. Meta Quest 3 | Yes. $600 (512 GB, reported) | Head and two wrist poses, or hand tracking | Head and wrist or hand poses | Unitree humanoids named; Franka arms in DROID (Quest 2) | Partly. Closed device; open software exists | No. You hire and train |
| 6. Apple Vision Pro | Yes. From $3,499 | Head, wrists and fingers by camera | Head, wrist and finger poses | Dexterous hands (Bunny-VisionPro); Unitree humanoids | Partly. Closed device; open software exists | No. You hire and train |
| 7. MANUS Metagloves Pro | No. Quote | 25 per hand (maker) | Finger joint angles | Dexterous hands; Shadow Hand system | No. Commercial, with SDK | No. You hire and train |
| 8. DOGlove | Yes. Under $600 (authors) | 21 captured; 5 force, 5 vibration | Finger joint angles | LEAP hand | Yes. Hardware and software | No. You hire and train |
| 9. AirExo | Yes. About $300 per arm (authors) | One-to-one with the arm’s joints | Joint positions, with or without robot | Flexiv Rizon; adaptable to UR5, Franka, Kuka | Yes. Open-source | No. You hire and train |
| 10. UMI gripper | No. Not stated | Gripper pose and width | Wrist-camera video, gripper pose and width | UR5e, Franka; jaw stroke over 85 mm | Yes. Code, hardware guide and build videos public | No. You hire collectors |
Three patterns stand out. First, the open designs are an order of magnitude cheaper than the commercial ones, and the gap is support, not capability: GELLO's authors built it for the Franka, the UR5 and the xArm, the same arms used in research labs7. Second, price tracks how much of the body is captured less than one would expect. A glove that measures 21 degrees of freedom with force feedback can be built for under $600 by its authors' account8, while a station that records two arms' joints costs forty times that. Third, no hardware row includes operators.
Published prices at a glance
| Hardware | Published price | What that buys |
|---|---|---|
| SO-101 pair | $229.88 in parts (US)1 | Leader and follower arm, 12 servos, printed by the buyer |
| SO-101 motor kit | $249.909 | Servos and driver boards for both arms, no printed parts |
| GELLO | Under $300 in parts, per its authors7 | One leader arm for a Franka, UR5 or xArm |
| AirExo | About $300 per arm, per its authors10 | A wearable exoskeleton mapped joint for joint to the robot arm |
| HOMIE cockpit | $500, per its authors11 | Exoskeleton arms, two gloves and a pedal for a humanoid |
| DOGlove | Under $600, per its authors8 | One glove with 21-DoF capture and force feedback |
| Meta Quest 3S, 128 GB | $350, reported April 202612 | Headset and two controllers |
| Meta Quest 3, 512 GB | $600, reported April 202612 | Headset and two controllers |
| Trossen Glide | $2,495 per arm; $6,995 for a pair with Cockpit13 | A passive, encoder-only leader arm and its station |
| Apple Vision Pro | From $3,49914 | Headset with bare-hand tracking |
| Trossen WidowX AI | $4,545.9515 | One arm, sold as leader or follower |
| ALOHA, self-built | A $20,000 budget, per its authors16 | Two leader and two follower arms with four cameras |
| Trossen Stationary AI | $23,995.952 | Four arms, four RealSense D405 cameras, touchscreen and frame |
| Trossen Mobile AI | $33,695.9515 | The two-arm station on a wheeled base |
| MANUS Metagloves Pro, HaptX Gloves G1, Shadow Teleoperation System | By quote345 | Commercial gloves and a complete dexterous-hand system |
What each controller puts in the dataset
Leader arms record joints. The operator moves a small copy of the robot and the robot follows joint for joint. ALOHA, which made the design popular, learned six fine bimanual tasks with 80 to 90% success from about ten minutes of demonstrations each17. GELLO's authors found that 12 users completed five tasks faster with a leader arm than with VR controllers or 3D mice7. The limit is that a leader matches one robot. The guide to kits and leader arms covers the SO-101, GELLO and the ALOHA line in detail.
Headsets record poses. A headset tracks the head and the controllers track the wrists18, so one device can drive many robots. The cost is a conversion step from pose to joint command, and hours in a headset. DROID's 76,000 trajectories were collected this way, with Quest 2 controllers, by 50 people at 13 institutions over 12 months19. See the guide to VR teleoperation.
Gloves and exoskeletons record fingers and whole arms. A robot hand with 20 degrees of freedom cannot be driven by a trigger5. Gloves measure each finger, and some push force back. Exoskeletons do the same for the arm and, for humanoids, pair with a pedal for walking11. See gloves and exoskeletons.
Handheld grippers record without a robot. UMI is a gripper with a camera that a person carries through the task. Its authors report 111 demonstrations an hour on a cup task against 35 for space-mouse teleoperation20. It cannot control a robot live, so it supplements a rig and does not replace one.
Delay matters for every live option. A round trip under roughly 100 to 150 milliseconds feels close to natural for direct manipulation, and above about 300 milliseconds continuous control becomes hard21. An operator in the same room is well inside that; one in another city may not be. RoboPilots publishes a free latency calculator that estimates the round trip between two locations and the control mode it supports22.
The line the hardware quote leaves out
A rig does nothing until someone is trained to use it, and that person is paid by the hour. The published figures for this work are consistent.
| Source | Pay | Notes |
|---|---|---|
| Study of 1,128 open postings at robotics, autonomous-vehicle and drone employers, October 202623 | Median $25 an hour | Only 24% of postings stated pay |
| Tesla, Optimus data collection operator, reported August 202424 | $25.25 to $48 an hour | Motion-capture suit and VR headset, three eight-hour shifts |
| Figure, humanoid robot operator, job posting25 | $30 to $45 an hour | Two to three weeks of training at headquarters |
| Public listings for contract teleoperators, 2026, as summarised by RoboPilots26 | About $20 to $55 an hour | Varies by country, role and skill |
Set against those rates, the hardware is small. By our arithmetic, at the $25 median an SO-101 pair costs about nine hours of one operator's pay. A Stationary AI kit costs about 960 hours, or 24 weeks of one full-time operator. A team that runs two shifts on that station spends more on wages than on the station within three months, before employer costs.
Training comes first and is paid too. Figure's posting describes a two-to-three-week training process before an operator works a shift25. At that posting's $30 base rate, our arithmetic puts the wage cost of training one operator at $2,400 to $3,600 before the first usable episode. The work is also tiring: tired operators produce hesitant, jerky demonstrations, so shifts need breaks and rotation18, and different operators solving a task in different ways add noise to the dataset18. The guide to hiring and training operators works through each cost.
The option most hardware buyers have not priced
Teams shopping for controllers usually assume the operators will be their own hires. There is an alternative that keeps the rig and changes who drives it. RoboPilots supplies remote pilots who are trained on the customer's robot before they run it, and who connect through the RoboPilots SDK or the customer's own teleoperation stack6. It keeps a stable pilot group per customer26, starts with a one-week trial that sets a baseline of clean episodes per operator hour27, shows live latency on the pilot's screen21 and returns sessions as labeled datasets in LeRobot, RLDS or HDF56. Its published starting price is $12 an hour, with everything above that quoted on the fleet2826.
The limits are specific. The pilots are remote, so scene resets and handling stay with the customer's staff. RoboPilots' pages do not say which controllers its pilots use, so a team with a leader-arm rig should ask how it would be driven over the network. And a starting price is not a quote. The comparison a team can make today is between a known hourly wage plus weeks of training on one side, and a one-week trial with a measured rate on the other.
The path from rig to first dataset
- Choose the controller from the robot, not the catalogue. One arm with a gripper: a leader arm. Several robots or a humanoid upper body: a headset. Fingers: a glove.
- Prove the pipeline on the cheapest rig that records the right signal. LeRobot's documentation suggests at least 50 episodes for a first task, with the cameras fixed29.
- Write the task protocol before adding people. The same start state, success criterion and failure handling for every operator18.
- Price the operators for the whole data plan. Hours needed, the wage, the weeks of training and who covers evenings and weekends.
- Compare that with trained pilots on the same rig. Run a short trial and measure clean episodes per operator hour.
- Scale the arrangement that holds its rate. Add stations only when the people to fill them are accounted for.
The end state is a rig that records the signal the policy needs, a written protocol, and operators, hired or contracted, who produce a known number of clean episodes each hour. At that point another station is a purchase order, and the cost of each episode is a measured number.
What hardware do you need for robot teleoperation?
A device that captures the operator's motion, cameras that show the operator what the robot sees, a computer that links the two and records, and a network. The capture device is the main choice. Leader arms copy the robot's joints, VR headsets track the head and hands, gloves track fingers, and exoskeletons track the whole arm.
How much does a teleoperation kit cost?
Published prices range from $229.88 in parts for an SO-101 leader and follower pair to $23,995.95 for Trossen's Stationary AI kit with four arms and four cameras. A GELLO leader arm costs under $300 in parts by its authors' account, a 512 GB Meta Quest 3 was reported at $600 in April 2026, and Apple Vision Pro starts at $3,499.
What is the best teleoperation controller?
It depends on the robot. For a single arm with a gripper, a leader arm gives the cleanest joint-space data. For a humanoid's upper body or several different robots, a VR headset is the usual choice. For a multi-fingered hand, a glove or a hand-tracking headset is needed.
Can you teleoperate a robot with a VR headset?
Yes. The headset tracks the head and the controllers or cameras track the hands, and software converts those poses into robot commands. The DROID dataset was collected with Quest 2 controllers, and Unitree's open software for its humanoids names Apple Vision Pro, PICO 4 Ultra Enterprise and Meta Quest 3.
What is a teleoperation glove?
A glove with sensors that measure finger joints so that a multi-fingered robot hand can copy them. MANUS Metagloves Pro capture 25 degrees of freedom per hand by the maker's account. HaptX Gloves G1 and the open-source DOGlove also push force back to the operator's fingers.
What is a leader arm?
A small arm with the same joints as the robot, moved by hand. The robot, called the follower, copies each joint. ALOHA, the SO-101 and GELLO all work this way, and the recording is a stream of joint positions that a policy can learn from directly.
How much do robot teleoperators get paid?
A study of 1,128 open postings at robotics, autonomous-vehicle and drone employers in October 2026 found a median of $25 an hour where pay was stated. Tesla advertised $25.25 to $48 an hour for Optimus data collection operators in 2024, and a Figure posting for humanoid operators listed $30 to $45 an hour.
Can a team hire trained teleoperators instead of training its own?
Yes. Managed services supply operators who learn the customer's robot and run it remotely. RoboPilots, for example, publishes a starting price of $12 an hour, trains pilots on the customer's robot and connects through its SDK or the customer's own teleoperation stack.
Sources
- SO-ARM100: standard open arms SO-100 and SO-101 (bill of materials). TheRobotStudio on GitHub. Accessed 11 Nov 2026.
- Stationary AI kit. Trossen Robotics. Accessed 11 Nov 2026.
- MANUS Metagloves Pro. MANUS. Accessed 11 Nov 2026.
- HaptX Gloves G1. HaptX. Accessed 11 Nov 2026.
- Shadow Teleoperation System. Shadow Robot. Accessed 11 Nov 2026.
- RoboPilots: remote robot operators and teleoperation as a service. RoboPilots. Accessed 11 Nov 2026.
- GELLO: a general, low-cost and intuitive teleoperation framework for robot manipulators. Wu, Shentu, Yi, Lin and Abbeel, UC Berkeley. Accessed 11 Nov 2026.
- DOGlove: Dexterous Manipulation with a Low-Cost Open-Source Haptic Force Feedback Glove. arXiv, 11 Feb 2025. Accessed 11 Nov 2026.
- SO-101 servo motor kit, LeRobot compatible. Seeed Studio. Accessed 11 Nov 2026.
- AirExo: low-cost exoskeletons for learning whole-arm manipulation in the wild. Fang et al. (ICRA 2024). Accessed 11 Nov 2026.
- HOMIE: humanoid loco-manipulation with isomorphic exoskeleton cockpit. Ben et al. (RSS 2025). Accessed 11 Nov 2026.
- Meta raises Quest 3 and Quest 3S prices. UploadVR, 16 Apr 2026. Accessed 11 Nov 2026.
- Glide leader arm and Cockpit station. Trossen Robotics. Accessed 11 Nov 2026.
- Apple Vision Pro upgraded with the M5 chip and Dual Knit Band. Apple Newsroom, 15 Oct 2025. Accessed 11 Nov 2026.
- Trossen AI: Stationary, Mobile, Solo and WidowX AI. Trossen Robotics. Accessed 11 Nov 2026.
- ALOHA: a low-cost open-source hardware system for bimanual teleoperation. Zhao, Kumar, Levine and Finn. Accessed 11 Nov 2026.
- Learning Fine-Grained Bimanual Manipulation with Low-Cost Hardware. arXiv, 23 Apr 2023. Accessed 11 Nov 2026.
- How to collect teleoperation data for robot learning. RoboPilots, 9 Oct 2026. Accessed 11 Nov 2026.
- DROID: a large-scale in-the-wild robot manipulation dataset. DROID dataset team. Accessed 11 Nov 2026.
- Universal Manipulation Interface: in-the-wild robot teaching without in-the-wild robots. Chi et al. (RSS 2024). Accessed 11 Nov 2026.
- Teleoperation latency: how much delay each robot task tolerates. RoboPilots, 31 Oct 2026. Accessed 11 Nov 2026.
- Teleoperation latency calculator. RoboPilots, 31 Oct 2026. Accessed 11 Nov 2026.
- Recruiting the people who train robots: what the first wave of hiring tells recruiters. Onrec, 22 Oct 2026. Accessed 11 Nov 2026.
- Tesla will pay up to $48 an hour to capture your movements. Decrypt, 19 Aug 2024. Accessed 11 Nov 2026.
- Humanoid Robot Operator, Figure (job posting, mirrored). Inference Jobs. Accessed 11 Nov 2026.
- Robot teleoperation as a service: how it works and what it costs. RoboPilots, 11 Nov 2026. Accessed 11 Nov 2026.
- Teleoperation service providers compared (2026). RoboPilots, 11 Nov 2026. Accessed 11 Nov 2026.
- Robot teleoperation pricing. RoboPilots. Accessed 11 Nov 2026.
- Imitation learning on real-world robots: teleoperate, record, train. Hugging Face LeRobot documentation. Accessed 11 Nov 2026.
Updated 11 Nov 2026: First published. Ten options compared on six criteria.